Publications

Research in aerial manipulation, robot perception, and learning-based planning. Papers, project details, and citations are collected below.

BibTeX

Conference Papers

conferences
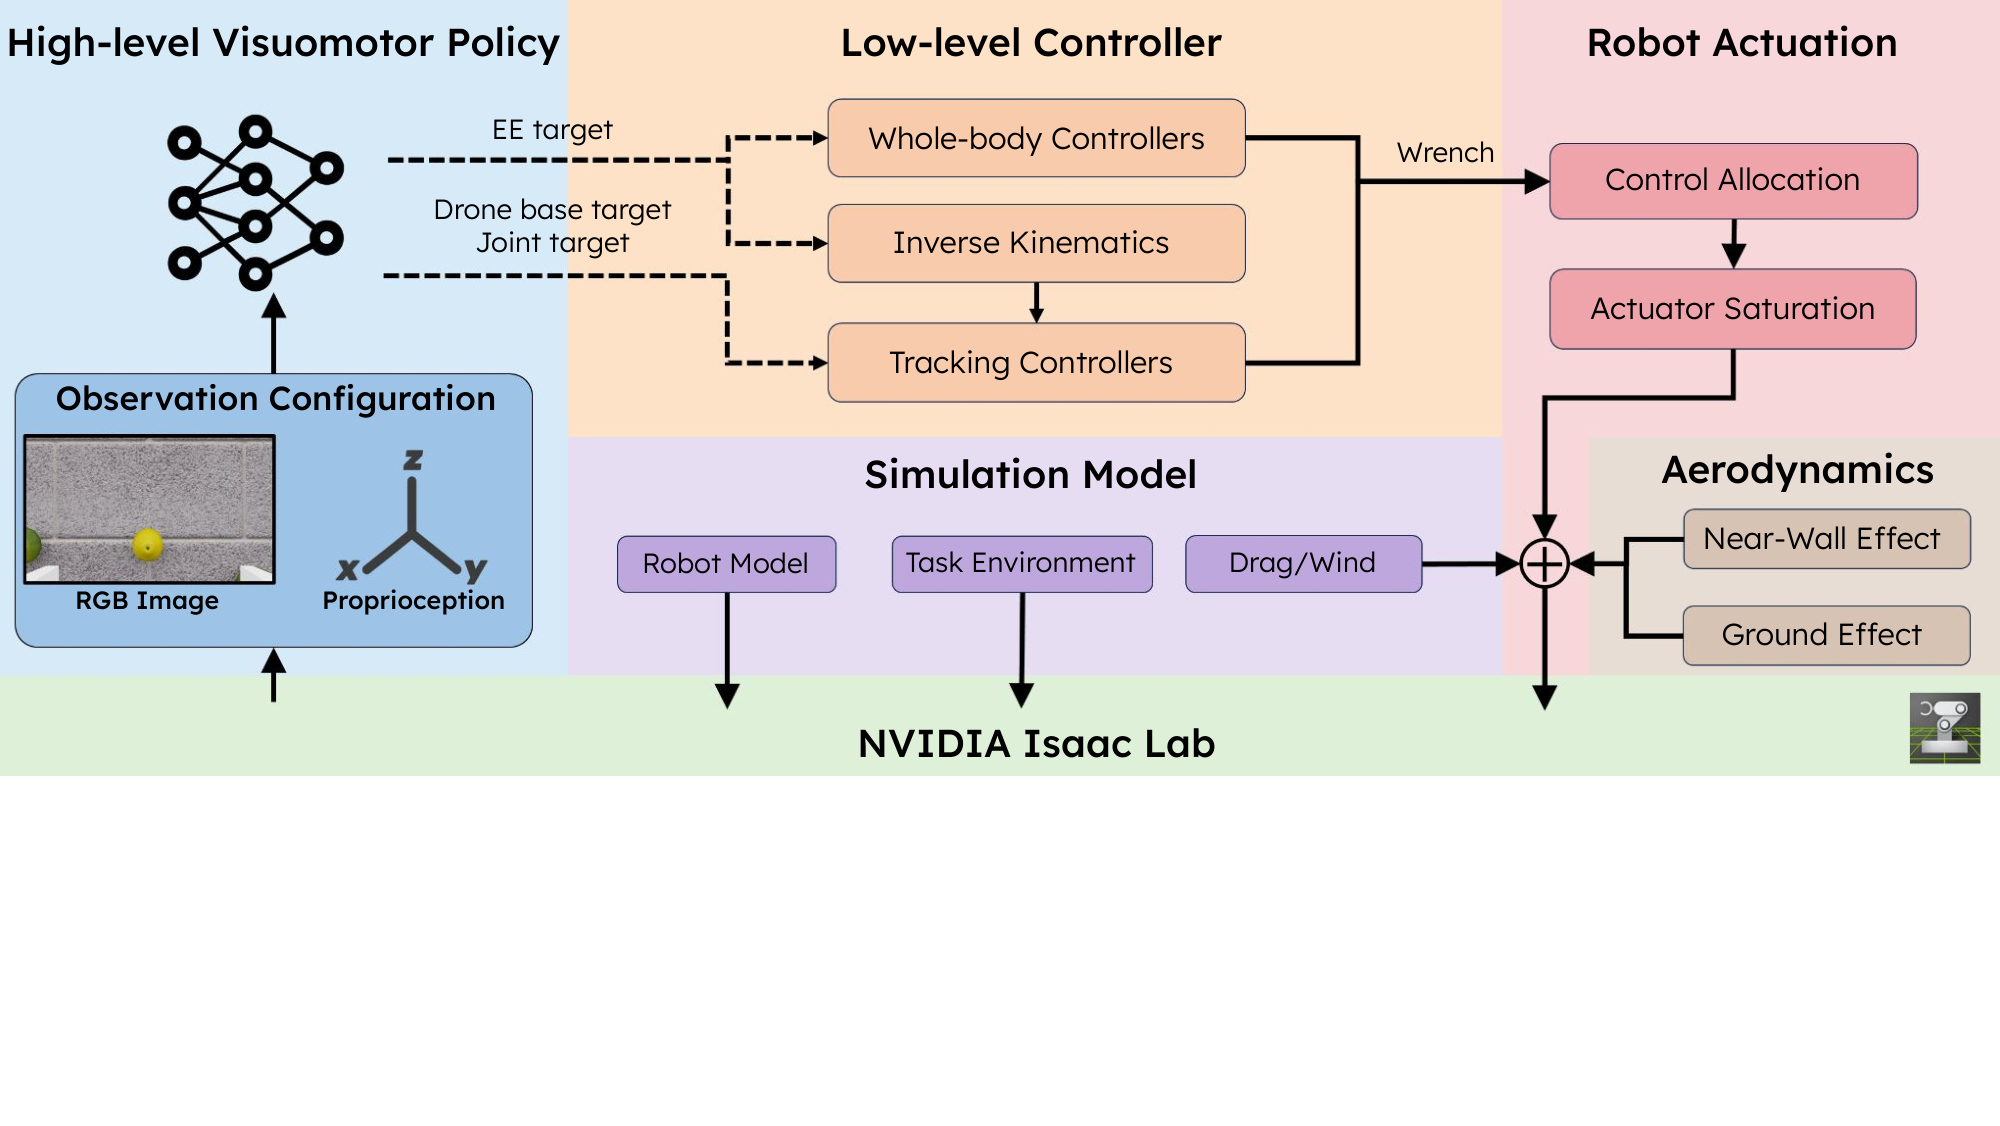
AM-Bench modular aerial manipulation simulation and learning architecture
2026 CoRL

AM-Bench: A Modular Simulation Suite and Benchmark for Aerial Manipulation Policy Learning

Y. Wang, D. Lee, X. Guo, Y. Zhan, Y. Jiang, B. Saravanan, M. Cao, J. Xie, C. Mao, S. Scherer, J. Geng, and G. Shi

Conference on Robot Learning (CoRL) · 2026

A modular simulation suite and benchmark for studying how aerial-robot embodiment, low-level control, disturbances, and policy design jointly affect manipulation performance.

2026 ICRA

A Self-Supervised Learning Approach with Differentiable Optimization for UAV Trajectory Planning

Y. Jiang*, Y. Zhan*, H. V. Gupta, C. Borde, and J. Geng

* Equal contribution

IEEE International Conference on Robotics and Automation (ICRA) · 2026

A self-supervised UAV planning framework that combines learned perception with differentiable trajectory optimization and adaptive time allocation.

Paper Project
2026 ICRA

Aerial Manipulation with Contact-Aware Onboard Perception and Hybrid Control

Y. Zhan*, Y. Jiang*, M. Cao, and J. Geng

* Equal contribution

IEEE International Conference on Robotics and Automation (ICRA) · 2026

A fully onboard perception–control pipeline for accurate motion estimation and stable, force-regulated aerial interaction without external motion capture.

Paper Project

Workshop Papers

workshops
2026

Aerial Manipulation in the Wild with Onboard Perception, Policy Learning, and Whole-Body Control

Y. Zhan*, Y. Jiang*, Z. Zhang, and J. Geng

* Equal contribution

5th Workshop on Mobile Manipulation and Embodied Intelligence (MoMA.v5), IROS 2026 · 2026

An outdoor aerial manipulation framework that combines an indoor-trained Diffusion Policy, onboard LiDAR–inertial odometry, and whole-body model predictive control.

Paper Project