Aerial Manipulation in the Wild
An outdoor aerial manipulation system combining onboard LiDAR–inertial odometry, a demonstration-trained Diffusion Policy, and whole-body model predictive control.
An outdoor aerial manipulation system combining onboard LiDAR–inertial odometry, a demonstration-trained Diffusion Policy, and whole-body model predictive control.
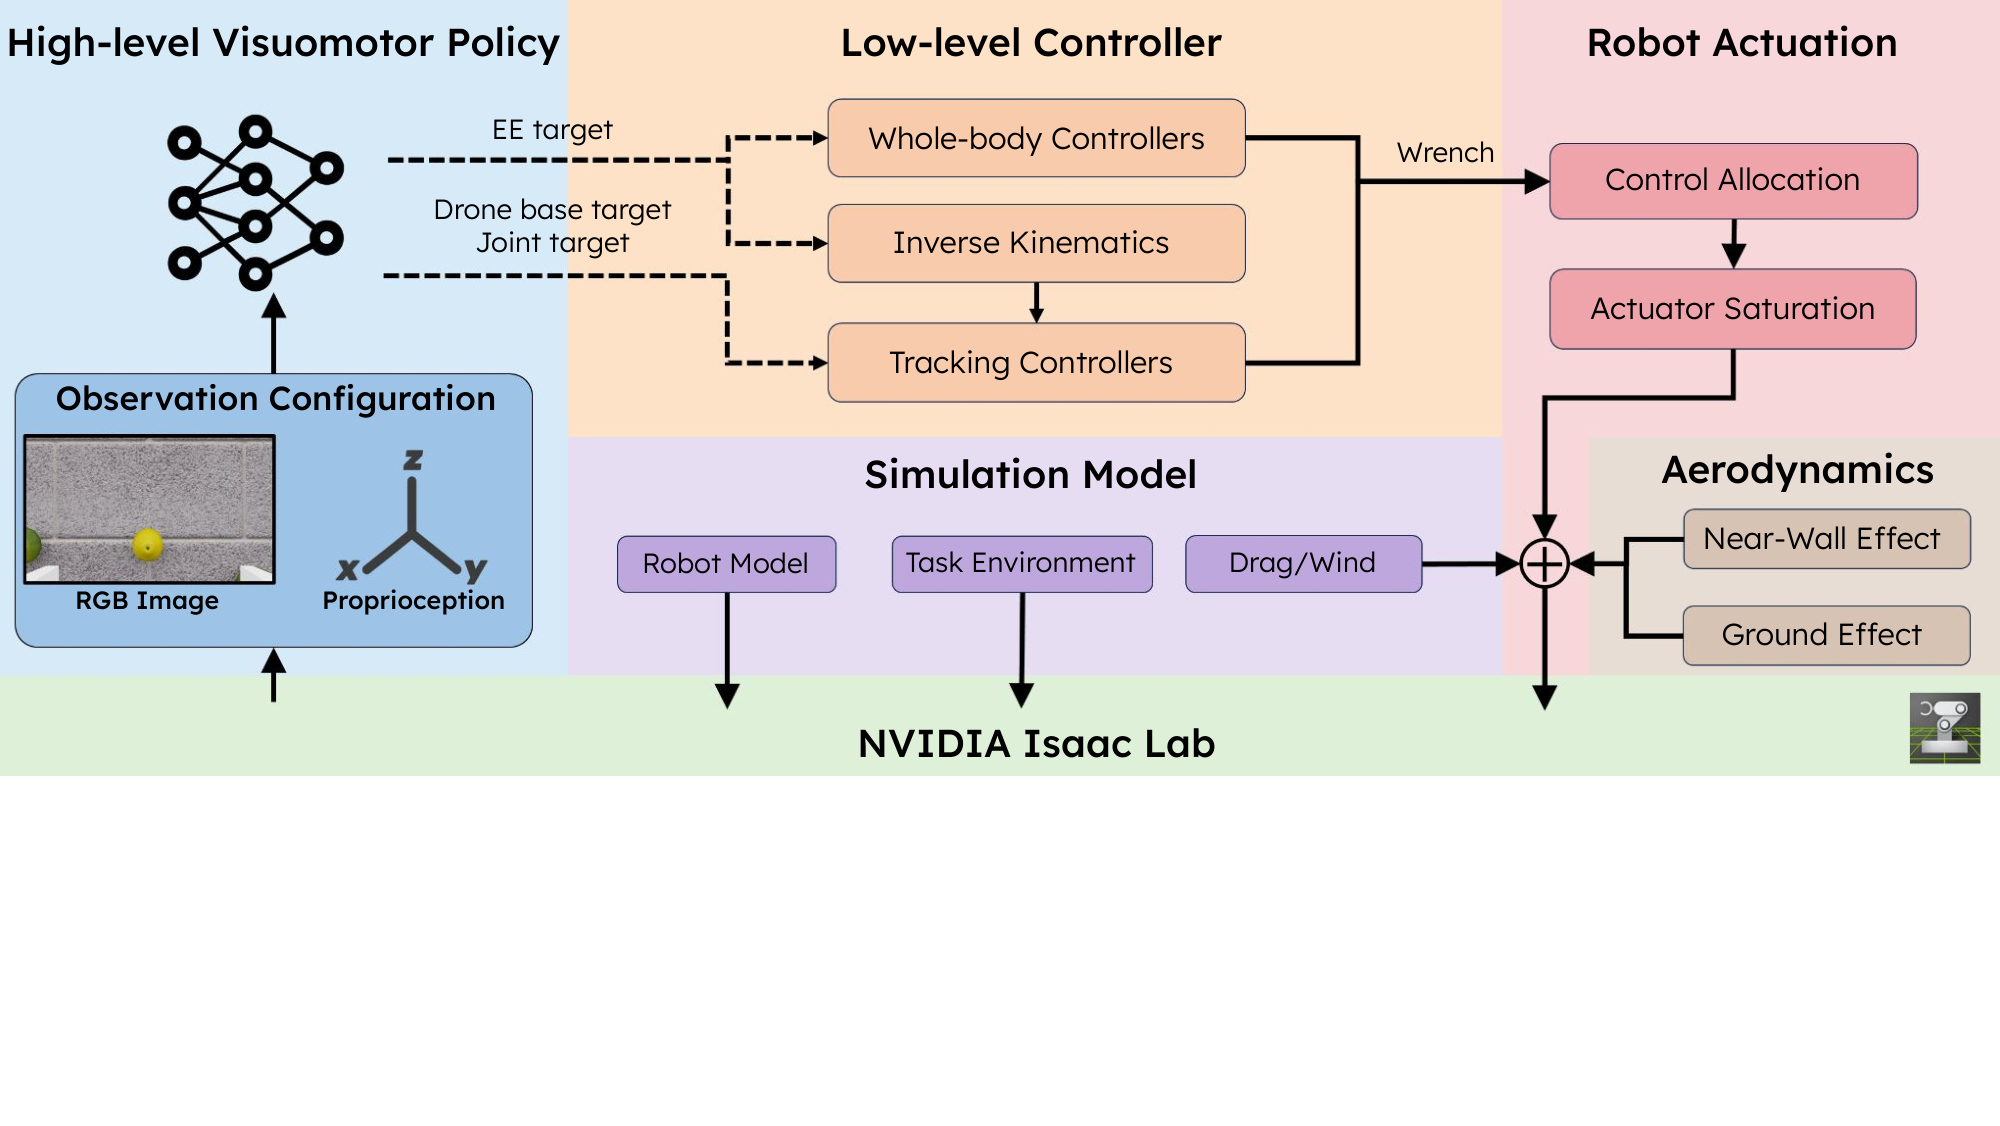
A modular simulation suite and benchmark for studying how aerial-robot embodiment, low-level control, disturbances, and policy design jointly affect manipulation performance.
A fully onboard perception and control system that enables an aerial manipulator to approach a target, establish contact, and regulate interaction forces without motion capture.
A self-supervised planning pipeline that combines learned depth perception with differentiable trajectory optimization for robust UAV navigation.
A multi-UAV exploration framework that allocates unknown regions while accounting for obstacle distribution and local environmental complexity.